Description
Core Product Summary (Brand / Model / Key Attributes)
The Galil Motion Control DMC-1040 is a four-axis motion controller in card-level format from Galil’s DMC-1000 series, an ISA-bus family of motion control boards. It provides programmable multi-axis control of servo and stepper motors from a host PC via the ISA bus, with motion intelligence — profiles, interpolation, and servo loops — executed on the controller itself rather than the host.
The DMC-1040’s four axes can be commanded independently for point-to-point moves, coordinated for linear and circular interpolation, or linked through electronic gearing and user-defined path following. A 32-bit microcomputer on board executes Galil’s English-like command language (over 200 commands with conditional statements and event triggers), with non-volatile memory for programs, variables, and arrays. Field I/O and amplifier interfacing are provided through the associated ICM-1100 interconnect module and AMP-series amplifier daughter boards of the DMC-1000 series. The controller is a legacy product within Galil’s Legacy Series (DMC-1500, 1300, 1000), which Galil has continued to support for its installed base.
Key Technical Specifications
| Parameter | Value |
|---|---|
| Product type | Card-level motion controller (ISA bus) |
| Model | DMC-1040 |
| Series | Galil DMC-1000 series (Legacy Series) |
| Axes | 4 independent motion axes |
| Host interface | ISA PC bus |
| Processor | 32-bit microcomputer |
| Motion modes | Jogging, point-to-point positioning, linear interpolation, circular interpolation, electronic gearing, user-defined path following; S-curve acceleration available |
| Motion parameters | Programmable acceleration/deceleration rates and slew speed per axis |
| Command language | Over 200 English-like commands; conditional statements and event triggers |
| Memory | Non-volatile memory for programs, variables, and arrays; -MX option expands to 2000 program lines, 8000 array positions, 510 variables (1–4 axis models) |
| Motor support | Servo and stepper motors |
| Encoder input | Accepts up to 12 MHz encoder frequencies for servos |
| Interconnect / options | ICM-1100 interconnect module; AMP-1110/1120/1130/1140 amplifier boards; -MX memory expansion; -HAEN/-LAEN high/low amp enable options |
| Software support | Galil Utilities, DMCWIN software and C/C++ examples (CToolkit); WSDK setup/tuning software; ActiveX Tool Kit |
| Position (series context) | DMC-1000 family spans DMC-1010 (1-axis) through DMC-1080 (8-axis), all ISA bus |
Detailed Product Overview
The DMC-1040 is the four-axis member of the DMC-1000 series, Galil’s ISA-bus generation of card-level motion controllers. In this architecture, the controller card plugs into an industrial or desktop PC’s ISA slot, while the drive and I/O connections break out through the ICM-1100 interconnect module — a separate terminal box that carries encoder inputs, command signals, limits, and general-purpose I/O to and from the machine. For integrated servo solutions, Galil’s AMP-series amplifier boards (AMP-1110 through AMP-1140) can be fitted, allowing the DMC-1000 system to drive motors directly from the controller family’s own amplifiers.
On the motion side, the controller provides the full feature set of Galil’s DMC command set: independent jogging and point-to-point positioning per axis, coordinated linear interpolation across axes (maintaining programmed vector speed, acceleration, and deceleration along the path), circular interpolation, and electronic gearing for following an external or internal master. S-curve acceleration profiles smooth the motion and reduce mechanical jerk. Parameters — speeds, accelerations, decelerations — are set per axis in the same command language.
Programming uses Galil’s English-like command set of more than 200 commands, including conditional statements and event triggers, downloaded to the controller’s non-volatile memory so the motion program executes on the controller without host intervention. Variables and arrays support data handling within programs; the -MX option expands memory for larger applications (2000 program lines, 8000 array positions, 510 variables on 1–4 axis models). Host software development is supported through Galil’s utilities — communication drivers, terminal, and DMCWIN with C/C++ documentation and examples — plus optional WSDK setup/tuning software and an ActiveX Tool Kit for Visual Basic and similar environments.
The DMC-1000 series covers one through eight axes — DMC-1010, -1020, -1030, -1040, -1050, -1060, -1070, and -1080 — with the DMC-1040 being the four-axis unit; the manual notes many examples written for the DMC-1040 or DMC-1080 as the typical configurations. As a member of Galil’s Legacy Series, the DMC-1040 remains supported by Galil alongside its successors (PCI-generation DMC-18×2/18×6 and the later Accelera and Econo families).
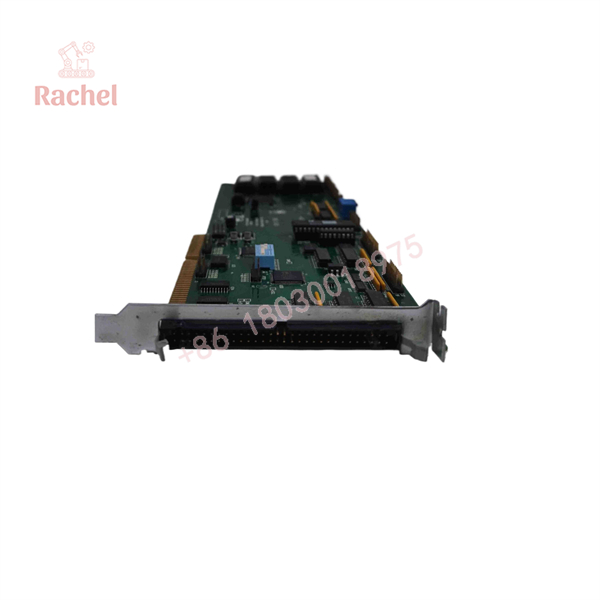
DMC-1040
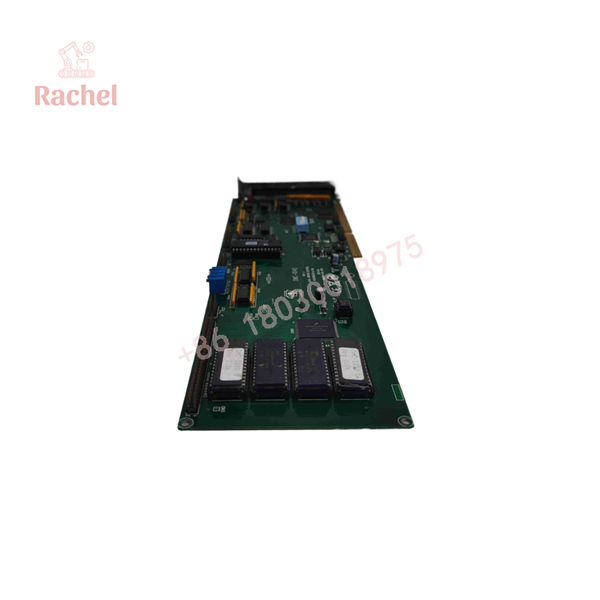
DMC-1040
System Compatibility & Integration Requirements
| Item / Dependency | Verified Compatibility or Requirement | Practical Note |
|---|---|---|
| Host bus | ISA PC bus slot | Controller is a card-level ISA board; PCI/PCIe hosts require a different Galil generation (DMC-18×2/18×6) |
| Axes | 4 axes, servo or stepper motors | Series spans DMC-1010 (1-axis) to DMC-1080 (8-axis) for other counts |
| Interconnect | ICM-1100 interconnect module | Carries encoder, limit, command, and I/O wiring to the machine |
| Amplifiers | External servo/stepper drives via ICM-1100, or Galil AMP-1110/1120/1130/1140 boards | ‘-HAEN/-LAEN option matches amplifier enable polarity |
| Encoders | Incremental encoder inputs up to 12 MHz (servos) | Verify resolution × max speed stays within the frequency limit |
| Cabling | 60-pin and 26-pin cables included (20-pin cables for steppers on request) | Specify cable set at ordering |
| Memory | Non-volatile memory for programs, variables, arrays; -MX expansion option | ‘-MX: 2000 lines, 8000 array positions, 510 variables (1–4 axis models) |
| Software | Galil Utilities (drivers, terminal, DMCWIN with C/C++ examples); WSDK; ActiveX Tool Kit | Command language shared across the DMC-1000 series |
| Support status | Legacy Series, supported by Galil | Successor families: DMC-18×2/18×6 PCI, DMC-40×0 Accelera, DMC-41×3 Econo |
Engineering Selection Highlights
- ISA host requirement — the controller requires an ISA-bus slot in the host PC; retrofit and replacement planning must account for host PC availability, as ISA slots disappeared from standard industrial PCs after the PCI generation.
- Axis count matching — four axes suit the most common machine configurations; Galil’s DMC-1000 series offers 1 through 8 axes (DMC-1010 through -1080) if the application’s axis count differs.
- Memory sizing — standard memory covers typical applications; specify the -MX option (2000 lines, 8000 array positions, 510 variables) for larger motion programs on 1–4 axis models.
- Amplifier architecture choice — decide between external amplifiers (commanding third-party servo drives via the ICM-1100) and Galil’s own AMP-series daughter boards for a tighter, integrated hardware set.
- Enable-signal polarity option — order -HAEN or -LAEN (high or low amp enable) to match the amplifier’s enable input polarity, avoiding interface rework at commissioning.
- Encoder frequency budget — the series accepts servo encoder frequencies up to 12 MHz; verify the machine’s encoder resolution and maximum speed stay within this limit.
- Stepper cabling note — the controllers ship with 60-pin and 26-pin cables; request 20-pin cables when driving steppers, per the series documentation.
- Software toolchain — plan for WSDK (setup, tuning, analysis) and the CToolkit/ActiveX toolkits as needed; the command set is shared across the DMC-1000 family, simplifying migration to Galil’s later controller generations.
- Legacy status — as a supported Legacy Series product, spares and repair channels exist, but new machine designs should evaluate Galil’s current Accelera or Econo families for long-term availability.
Dimensions, Mounting & Connection Notes
- Format: card-level motion controller installed in a host PC’s ISA slot
- Interconnect: machine wiring via the ICM-1100 module (encoders, limits, I/O, amplifier commands)
- Cables: 60-pin and 26-pin cables included with the controller; 20-pin cables available for stepper applications
- Amplifier boards: optional AMP-1110 through AMP-1140 daughter boards for integrated motor drives
- Enable options: -HAEN / -LAEN factory options for high or low amplifier enable signal level
FAQ
What is the Galil DMC-1040?
It is a four-axis, card-level motion controller from Galil’s DMC-1000 series, installed in a host PC’s ISA bus slot and programmed with Galil’s English-like command language to control servo and stepper motors.
How many axes does it control?
Four axes, which can move independently, coordinate in linear and circular interpolation, or link via electronic gearing.
What motion functions does it provide?
Jogging, point-to-point positioning, linear and circular interpolation, electronic gearing, user-defined path following, and S-curve acceleration smoothing, with programmable speeds, accelerations, and decelerations per axis.
How is it programmed?
Through Galil’s command set of over 200 English-like commands, including conditional statements and event triggers, stored in non-volatile memory. Host development is supported with DMCWIN C/C++ examples, the WSDK tuning package, and an ActiveX Tool Kit.
What is the ICM-1100?
The interconnect module of the DMC-1000 system that breaks out the controller’s encoder inputs, command signals, limits, and I/O to terminal-level machine wiring.
Can it drive motors directly?
With the optional AMP-1110 through AMP-1140 amplifier boards, the DMC-1000 system provides integrated servo amplification; otherwise, it commands external drives through the ICM-1100.
What does the -MX option do?
It expands the controller’s memory to 2000 program lines, 8000 array positions, and 510 variables on 1–4 axis models.
Is the DMC-1040 still supported?
Yes. It belongs to Galil’s Legacy Series (DMC-1500, 1300, 1000), which Galil continues to support for the installed base; new designs typically use the current Accelera or Econo families.
Verification & Troubleshooting Notes
- Controller not detected by host: verify the ISA card is fully seated and the host PC’s ISA slot and configuration (address/interrupt settings) match the Galil driver setup; ISA-era resource conflicts are a common cause.
- Axes do not move: check the amplifier enable chain first — the -HAEN/-LAEN option must match the amplifier’s enable polarity, and the ICM-1100 enable wiring must be intact.
- Position drift or following errors: verify encoder connections at the ICM-1100 (quadrature A/B wiring, shielding) and confirm the encoder frequency at maximum speed is within the 12 MHz input limit.
- Coordinated moves skew between axes: confirm the interpolation command sequence in the motion program (vector speed, acceleration settings) and that all participating axes’ drives are properly tuned using WSDK.
- Program lost after power-down: the controller stores programs in non-volatile memory — if programs vanish, check that the download and burn-to-memory sequence completed correctly, and that the -MX memory configuration matches the program size.
- Daughter-board faults: if an AMP-series amplifier board is fitted, isolate faults by swapping the board with a known-good unit before replacing the DMC-1040 itself.
- Host PC replacement planning: because ISA slots are obsolete, plan host PC lifecycle carefully — when the ISA host finally fails, migration to a Galil PCI-generation or Ethernet controller (with command-set porting, which is largely compatible across the DMC families) is the practical path.
- Always power down the host PC and machine before inserting or removing the controller card or amplifier boards, and observe ESD precautions when handling the cards.

 Start Chat


