Description
Core Product Summary (Brand / Model / Key Attributes)
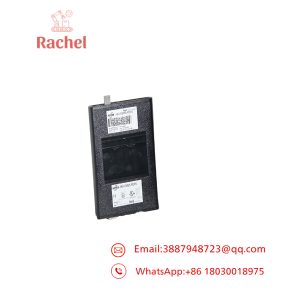
The ROLLS-ROYCE H1111.0103 is a marine controller identified with PIC code 75669 and PIC Revision 2.2. It is used in Rolls-Royce vessel automation and propulsion-control architectures, where it performs control, monitoring, and signal-processing functions for marine equipment.
The controller is associated with an H6029 processor operating at 300 MHz. It is identified in marine-equipment records as a Rolls-Royce marine controller rather than a general-purpose PLC. For replacement or integration, the installed PIC revision, application configuration, communication topology, and vessel-specific control database should be matched before substituting the unit.
Key Technical Specifications
| Attribute | Verified Information |
|---|---|
| Manufacturer | ROLLS-ROYCE |
| Exact model / part number | H1111.0103 |
| Product type | Marine controller |
| Associated PIC code | 75669 |
| PIC revision | Rev 2.2 |
| Processor | H6029, 300 MHz |
| Application area | Marine propulsion, steering management, and vessel automation |
| System role | Control, feedback processing, and vessel-system monitoring |
Detailed Product Overview
The ROLLS-ROYCE H1111.0103 is a marine controller used within Rolls-Royce ship automation and propulsion-control systems. It is identified with PIC code 75669 and PIC Revision 2.2, and is equipped with an H6029 processor running at 300 MHz.
Its documented role is to handle control and feedback-processing tasks in marine propulsion and steering-management applications. Published equipment references associate the controller with propulsion control, dynamic positioning, Azipod propulsion control, and integrated bridge maneuvering systems. These functions require the controller to work as part of a vessel-specific automation architecture rather than as an isolated control device.
For procurement and replacement, the H1111.0103 designation alone is not sufficient to establish functional interchangeability. The installed PIC revision, application software or control database, communication configuration, and connected propulsion or automation equipment must be consistent with the original controller. A replacement should therefore be verified against the removed unit and the vessel’s Rolls-Royce system documentation before installation.
Because this is a marine control controller, electrical isolation, lockout/tagout, and electrostatic-discharge precautions apply during removal or installation. Configuration records, connector positions, and network settings should be documented before the original unit is disconnected.
H1111.0103
Engineering Selection Highlights
- Exact H1111.0103 identification → The full model number confirms a Rolls-Royce marine controller rather than a generic industrial PLC.
- PIC code 75669 / Rev 2.2 → These identifiers help distinguish the installed controller configuration and should be matched during replacement.
- H6029 300 MHz processor → The processor identification supports verification of the controller hardware against the original unit.
- Marine propulsion and steering role → The controller is intended for vessel propulsion, steering management, and automation applications, not standalone factory-floor control.
- System-level integration requirement → Propulsion, dynamic positioning, Azipod, and bridge-maneuvering functions depend on the surrounding Rolls-Royce automation architecture and vessel-specific configuration.
- Configuration-dependent replacement → Firmware, PIC revision, application configuration, communication topology, and control database must align with the installed system.
System Compatibility & Integration Requirements
| Item / Dependency | Verified Compatibility or Requirement | Practical Note |
|---|---|---|
| Manufacturer system | Rolls-Royce marine automation and propulsion-control architecture | The controller is intended for use within Rolls-Royce vessel systems. |
| Controller identification | PIC code 75669, PIC Rev 2.2 | Match these identifiers with the installed controller before replacement. |
| Processor hardware | H6029, 300 MHz | Use this hardware identifier to help verify the controller version. |
| Application area | Marine propulsion, steering management, dynamic positioning, Azipod propulsion, and bridge maneuvering systems | Confirm the vessel application and connected control equipment before installation. |
| Configuration dependency | Vessel-specific control database and communication topology | A replacement must match the original controller’s system configuration. |
Dimensions, Mounting & Connection Notes
- The H1111.0103 is a marine controller intended for installation within a Rolls-Royce vessel automation or propulsion-control system.
- Before removal, record connector positions, network connections, power connections, grounding arrangements, and any configuration switches or jumpers.
- Use electrostatic-discharge protection when handling the controller.
- Ensure the associated control system is de-energized and locked out before disconnecting or installing the unit.
FAQ
What is the ROLLS-ROYCE H1111.0103?
It is a Rolls-Royce marine controller identified with PIC code 75669 and PIC Revision 2.2.
What is the H1111.0103 used for?
It is used in Rolls-Royce vessel automation and propulsion-control systems for control, feedback processing, and monitoring functions.
Which processor does it use?
The controller is associated with an H6029 processor operating at 300 MHz.
What does PIC code 75669 mean?
It is the controller identification code associated with the H1111.0103; the documented revision is Rev 2.2.
Can it be used in dynamic positioning systems?
Published marine-equipment references associate the controller with dynamic positioning, Azipod propulsion control, and integrated bridge maneuvering systems.
Is matching the model number enough for replacement?
No. The PIC revision, application configuration, communication topology, and vessel-specific control database should also be matched.
Verification & Troubleshooting Notes
- Confirm the controller marking reads H1111.0103 and record the associated PIC code and revision before replacement.
- Compare the removed unit’s PIC revision, processor identification, connectors, configuration settings, and network topology with the replacement.
- If a propulsion, steering, or automation fault occurs, distinguish between a controller issue and possible causes in power supply, field wiring, communication links, sensors, actuators, or vessel-specific configuration.
- Do not replace or alter application software, control databases, or safety-related configurations without following the vessel’s approved Rolls-Royce system procedures.
- Keep the control system de-energized and locked out during inspection or replacement, and use appropriate ESD-handling procedures.

 Start Chat


