Description
Core Product Summary (Brand / Model / Key Attributes)
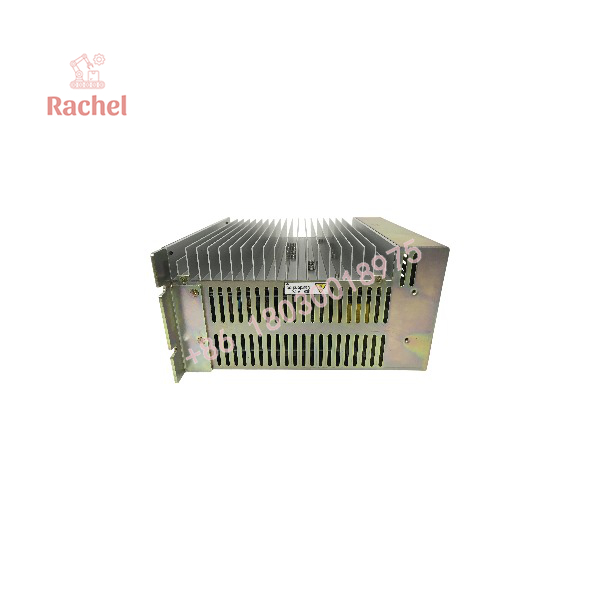
The NSK ESA-1010A35-21 is an ESA35-series driver unit for the NSK Megatorque Motor System. Its reference number identifies it as a drive for an RS1010 Megatorque motor with a 200/220 V AC main-power configuration and the standard ESA35 driver specification.
The ESA-1010A35-21 provides closed-loop control of a compatible direct-drive Megatorque motor through resolver feedback. It supports position, velocity, and torque control modes, pulse-train and analog commands, programmable indexer operation, RS-232C communication, and control I/O through CN2 and CN5. The driver uses EEPROM backup for programs and parameters, so it does not require a battery for memory retention. It must be paired with the matching RS1010 motor and specified cable set; NSK states that motor/driver interchangeability is not applicable to ESA35 and ESAC5 systems.
Key Technical Specifications
| Attribute | Value |
|---|---|
| Brand | NSK |
| Model | ESA-1010A35-21 |
| Product type | ESA35 driver unit for Megatorque Motor System |
| Motor family | Megatorque direct-drive servo motor |
| Identified motor size | RS1010 |
| Main power configuration | A = 200/220 V AC |
| Driver configuration | 35 = standard ESA35 driver |
| Main supply range | 200–220 V AC ±10% |
| Control-power supply | 100–220 V AC ±10%, 50/60 Hz, single phase |
| Control-power capacity | Maximum 50 VA, excluding inrush current |
| Inrush current | 14 A at 200 V AC; 7 A at 100 V AC |
| Feedback | Resolver |
| Control modes | Position, velocity, and torque control |
| Command interfaces | Pulse train, analog velocity/torque command, RS-232C |
| Communication | RS-232C serial communication; daisy-chain communication supported |
| Programming | Handy Terminal FHT11 via CN1; programmable indexer channels |
| Parameter/program storage | EEPROM; no memory-backup battery required |
| Motor connector | CN4 |
| Resolver connector | CN3 |
| Control I/O connectors | CN2 and CN5 |
| Serial/setup connector | CN1 |
| Ambient operating temperature | 0 to 50 °C |
| Enclosure requirement | Install in an enclosure rated IP54 or better |
| Installation clearance | 100 mm above and below the driver unit |
Detailed Product Overview
The NSK ESA-1010A35-21 belongs to the ESA35 driver-unit family used with NSK Megatorque direct-drive motors. The model designation breaks down as an ESA driver for an RS1010 motor, configured for a 200/220 V AC main supply and standard ESA35 functionality. The trailing -21 is a model/order suffix that should be matched against the installed unit nameplate and system records.
As the drive element of a Megatorque system, the ESA-1010A35-21 closes the servo loop using resolver feedback from the motor. It provides the control functions required for direct-drive motion applications, including positioning, velocity control, torque control, homing, jog operation, overtravel protection, alarm handling, and programmable indexer sequencing. Commands can be supplied through pulse-train inputs, analog velocity or torque inputs, internal program channels, or RS-232C communication.
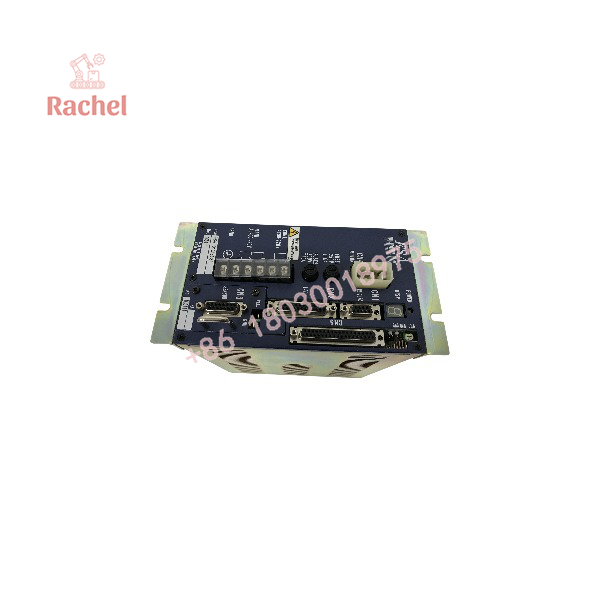
The driver provides dedicated system interfaces: CN1 for RS-232C communication and Handy Terminal connection, CN2 and CN5 for control I/O, CN3 for the resolver cable, and CN4 for the motor cable. The Handy Terminal FHT11 connects to CN1 and is used for parameter entry, monitoring, program handling, and system setup. Parameters and programs are retained in EEPROM, eliminating the need for a memory-backup battery.
A critical integration constraint is motor-and-driver pairing. NSK specifies that ESA35 and ESAC5 driver units are not interchangeable between motors and that the motor and driver should have matching serial numbers. The driver retains motor-specific parameters, and using a mismatched pairing or altering the cable-set length can reduce positioning performance, increase noise, and degrade home-return repeatability—particularly in systems equipped with absolute position sensing.
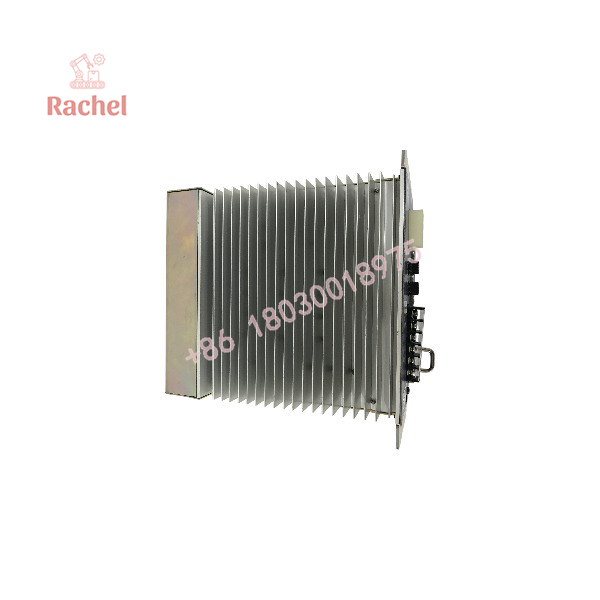
Installation must provide adequate thermal and environmental protection. NSK specifies an ambient range of 0 to 50 °C, 100 mm clearance above and below the unit, and installation in an enclosure rated IP54 or better. The driver must be protected from oil mist, cutting fluid, metal chips, paint fumes, water, and conductive contamination.
Engineering Selection Highlights
- ESA-1010A35 identifies an RS1010 Megatorque motor drive with 200/220 V AC main power, so the connected motor must be an RS1010 configuration and the supply architecture must match the A-coded power designation.
- The ESA35 platform uses resolver feedback and supports position, velocity, and torque control, making it suitable for direct-drive servo applications requiring closed-loop motion control.
- CN1, CN2, CN3, CN4, and CN5 define the required interface set, covering serial/setup communication, control I/O, resolver feedback, motor power/signals, and additional I/O.
- The Handy Terminal FHT11 connects at CN1 and is the documented tool for parameter entry, monitoring, and programming.
- EEPROM retention removes the need for a battery-backed memory, simplifying replacement planning but making parameter and program backup still important before servicing.
- NSK requires matched motor/driver serial numbers and the specified cable set, so a replacement drive cannot be selected on model number alone.
- The 0–50 °C ambient limit, IP54-or-better enclosure requirement, and 100 mm vertical clearance determine cabinet suitability.
ESA-1010A35-21
ESA-1010A35-21
ESA-1010A35-21
Dimensions, Mounting & Connection Notes
- Maintain 100 mm clearance above and below the driver unit inside the enclosure.
- Install the drive in an enclosure with IP54 or better protection.
- Protect the unit from oil mist, cutting oil, metal chips, paint fumes, water, and corrosive gas.
- Connect the FG terminal to one-point ground; ground the motor and driver respectively according to the NSK wiring guidance.
- Use the documented connectors: CN1 for RS-232C/Handy Terminal, CN2 and CN5 for control I/O, CN3 for resolver feedback, and CN4 for the motor.
- Lock connectors securely and check fixing screws; do not modify the cable set.
- Do not perform a megger test on the driver unit, as this can damage internal circuitry.
- After removing main and control power, wait at least five minutes before removing covers because internal capacitors can retain a hazardous residual voltage.
System Compatibility & Integration Requirements
| Item / Dependency | Verified Compatibility or Requirement | Practical Note |
|---|---|---|
| Motor family | NSK Megatorque Motor System | The drive is part of NSK’s direct-drive Megatorque platform. |
| Motor size | The ESA-1010A35 designation identifies an RS1010 motor drive configuration. | |
| Motor pairing | Motor and driver must have matching serial numbers | NSK states ESA35/ESAC5 motor-driver interchangeability is not applicable. |
| Motor-specific parameters | Driver retains unique motor parameters | A mismatched motor/driver combination can reduce precision and increase noise. |
| Cable set | Use the specified NSK cable set | Do not shorten, extend, reroute, or modify the cable set. |
| Main power | 200–220 V AC ±10% | Match the A-coded main-power configuration. |
| Control power | 100–220 V AC ±10%, 50/60 Hz, single phase | Confirm both main and control supplies before power-up. |
| Feedback | Resolver via CN3 | Use the correct resolver cable and verify resolver-related alarms if feedback issues occur. |
| Setup/communication | RS-232C at CN1; Handy Terminal FHT11 | Use the Handy Terminal for parameters, monitoring, and program functions. |
| Control I/O | CN2 and CN5 | Includes servo-on, run, in-position, alarm, emergency-stop, and command interfaces. |
| Environment | 0–50 °C ambient; IP54-or-better enclosure; 100 mm vertical clearance | Provide ventilation or cooling if heat accumulates above the drive. |
FAQ
What is the NSK ESA-1010A35-21?
It is an NSK ESA35 driver unit for the Megatorque Motor System, configured for an RS1010 Megatorque motor and a 200/220 V AC main supply.
Which motor does the ESA-1010A35-21 drive?
The model designation identifies compatibility with an RS1010 Megatorque motor configuration.
What does the “A35” portion of the model number mean?
In NSK’s ESA reference-number structure, A identifies a 200/220 V AC main-power configuration and 35 identifies the standard ESA35 driver unit.
Does the ESA-1010A35-21 require a memory-backup battery?
No. ESA35 and ESAC5 driver units use EEPROM to retain programs and parameter settings.
How is the drive configured and monitored?
The Handy Terminal FHT11 connects to CN1 for parameter entry, monitoring, program functions, and RS-232C communication.
Can an ESA-1010A35-21 be used with a different Megatorque motor?
No. NSK states that motor/driver interchangeability is not applicable to ESA35 and ESAC5 systems; the motor and driver must be serial-number matched.
What installation environment does NSK specify?
The drive requires a 0–50 °C ambient temperature, an IP54-or-better enclosure, and 100 mm clearance above and below the unit.
What control interfaces are available?
The drive supports pulse-train commands, analog velocity and torque commands, RS-232C communication, programmable indexer operation, and control I/O through CN2 and CN5.
Verification & Troubleshooting Notes
- Verify the complete nameplate, including , motor designation, serial number, and any revision or suffix markings.
- Confirm that the connected RS1010 motor and driver serial numbers match before commissioning or replacing either unit.
- Check both main power and control power against the specified ranges; the manual identifies abnormal main AC voltage and control AC undervoltage as alarm conditions.
- If the motor will not operate, check the SVON, RUN, and IPOS signal states through the Handy Terminal I/O monitor and verify stable 24 V control-power and input-signal levels.
- For vibration, positioning error, or frequent software-thermal alarms, review servo parameters VG, VI, PG, FP, and NP, mechanical mounting, load fixing, grounding, and external interference in servo lock.
- For repeated breaker trips, NSK recommends evaluating the power-up inrush condition and considering a delay-type breaker.
- Do not disassemble the Megatorque motor, modify the cable set, or perform a megger test on the driver.
- Always connect the emergency-stop circuit to the EMST port and maintain the documented safety-stop arrangement.

 Start Chat


